2026

Online learning of heterogeneous locomotion dynamics for precise loco-manipulation
Online Learning of Heterogeneous Locomotion Dynamics under Reinforcement Learning Policies for Precise Loco-Manipulation
Tianlin Zhang, Weipeng Xia, Lingwei Zhang, Yiyang Shao, Zhongyu Li, Yun-Hui Liu
arXiv preprint, arXiv:2610.41892, 2026
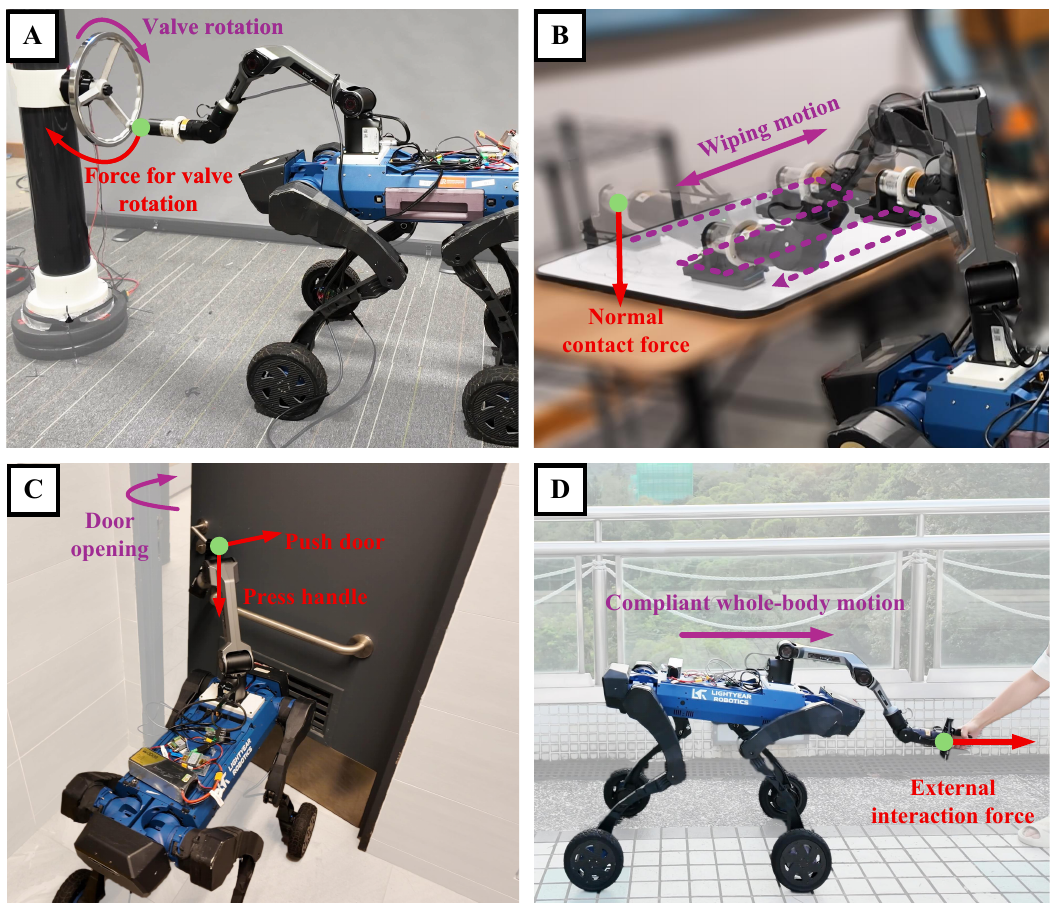
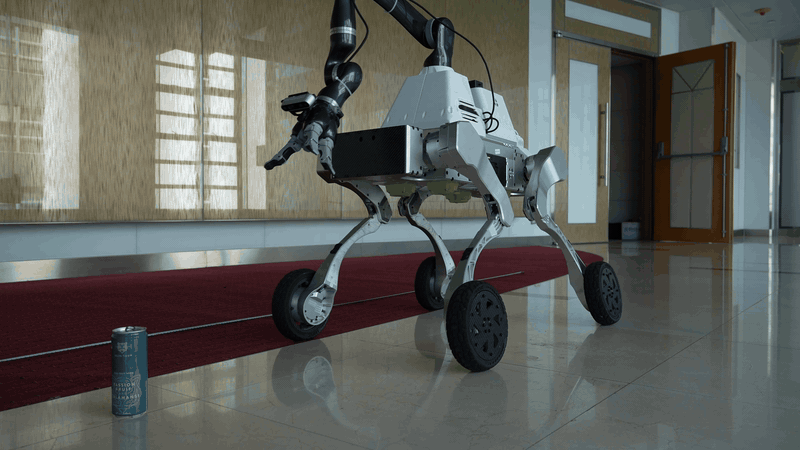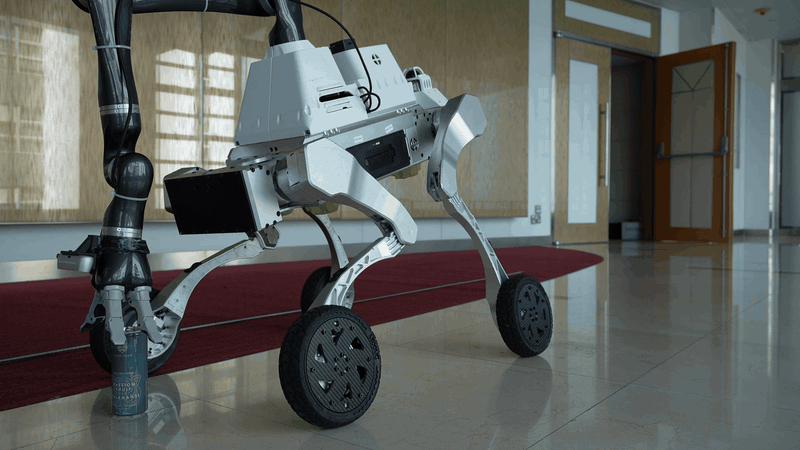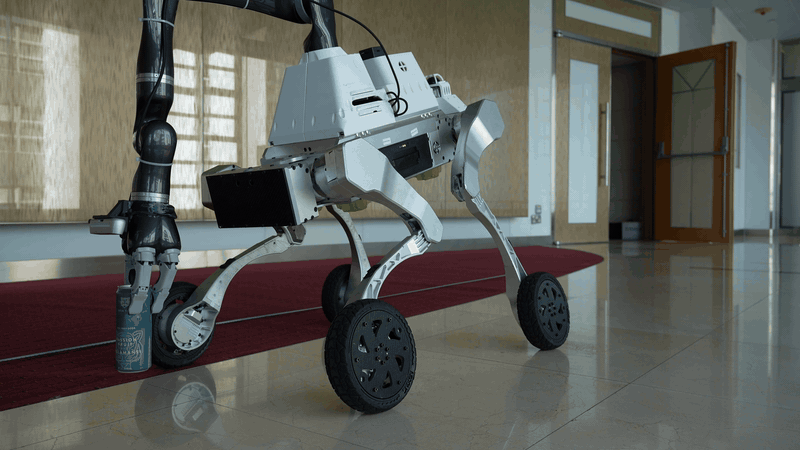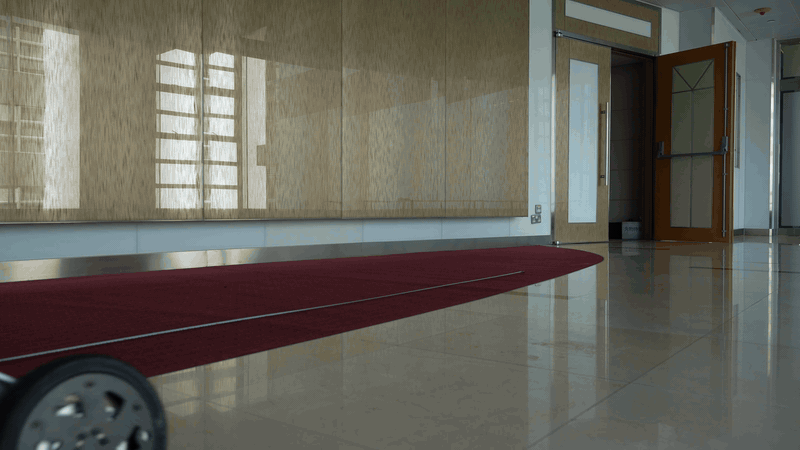
Force-aware wheeled-legged robot performing valve rotation, wiping, door opening, and human-guided motion
Force-Aware Reinforcement Learning with Hybrid Sensorless Force Estimation for Wheeled-Legged Loco-Manipulation
Xuanqi Zeng, Jiaming Wang, Tianlin Zhang, Lingwei Zhang, Botian Xu, Weipeng Xia, Zhongyu Li, Yun-Hui Liu
arXiv preprint, arXiv:2609.13779, 2026
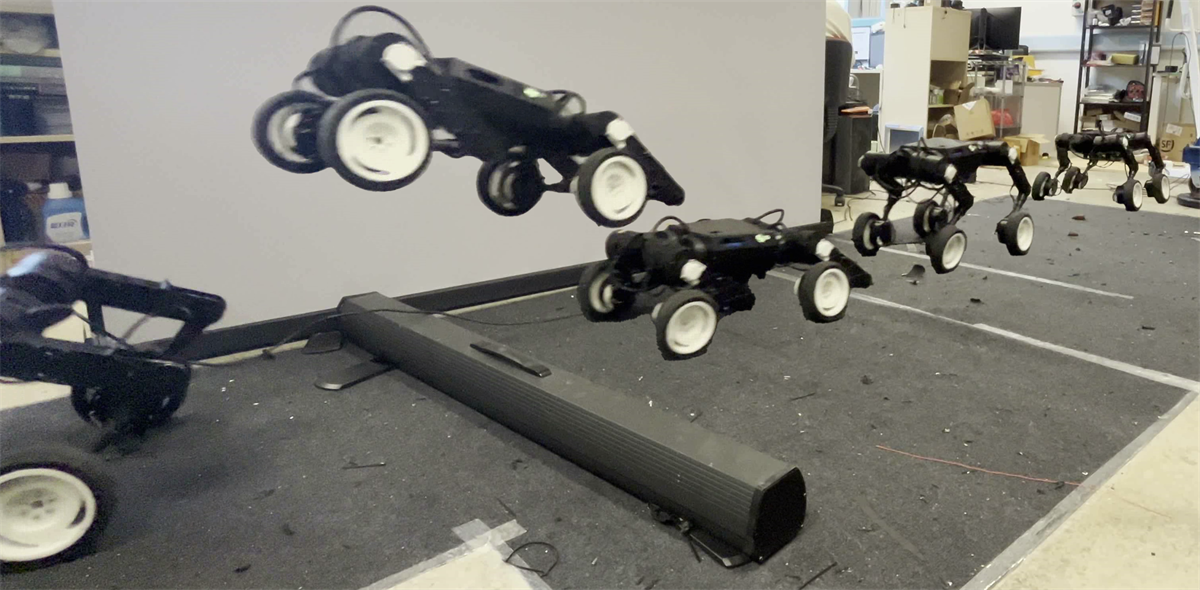
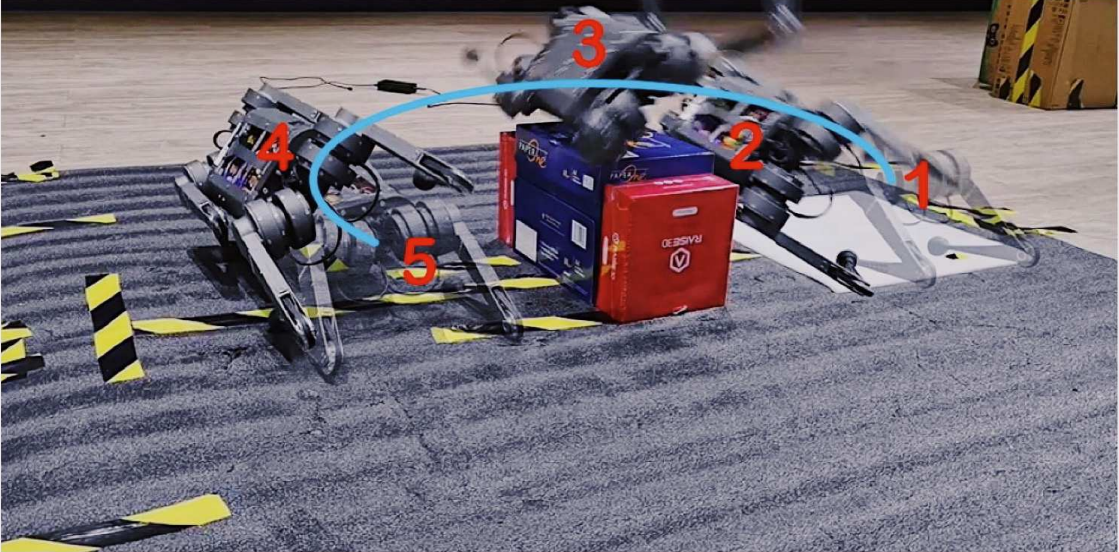
Quadrupedal wheeled-legged robot jumping over an obstacle
Jumping Control for a Quadrupedal Wheeled-Legged Robot via NMPC and DE Optimization
Xuanqi Zeng, Lingwei Zhang, Linzhu Yue, Zhitao Song, Hongbo Zhang, Tianlin Zhang, Yun-Hui Liu
arXiv preprint, arXiv:2602.21612, 2026
VRA
VRA: Grounding Discrete-Time Joint Acceleration in Voltage-Constrained Actuation
Lingwei Zhang, Jiaming Wang, Tianlin Zhang, Zhitao Song, Xuanqi Zeng, Weipeng Xia, Zhongyu Li, Yun-hui Liu
Robotics: Science and Systems (RSS), 2026
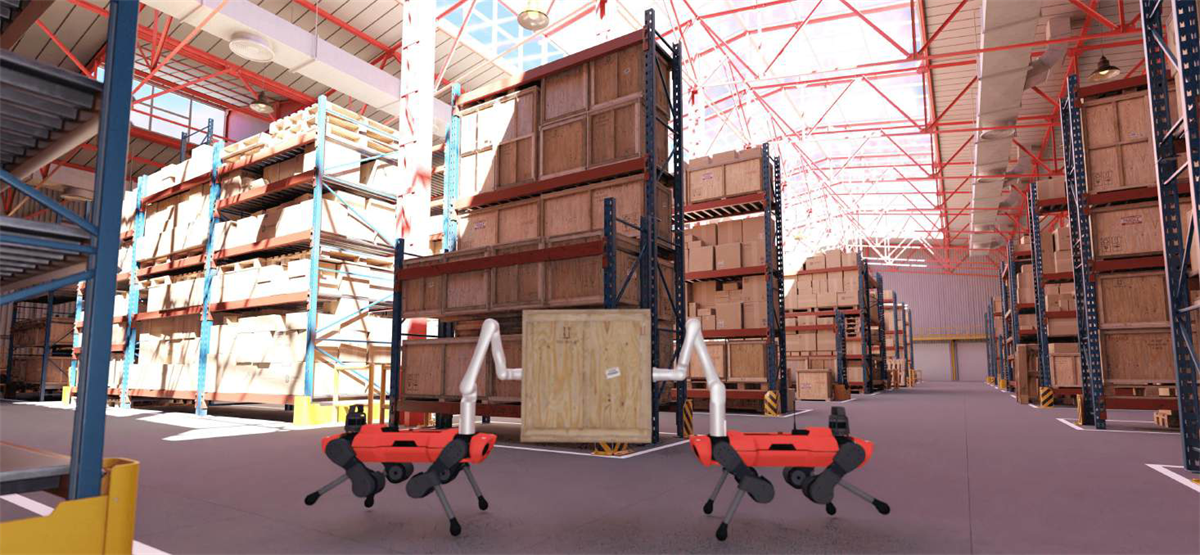
A team of collaborative quadrupeds manipulating and transporting an object
Shared Object Manipulation with a Team of Collaborative Quadrupeds
Shengzhi Wang, Niels Dehio, Xuanqi Zeng, Xian Yang, Lingwei Zhang, Yun-Hui Liu, K. W. Samuel Au
American Control Conference (ACC), IEEE, 2026

2025
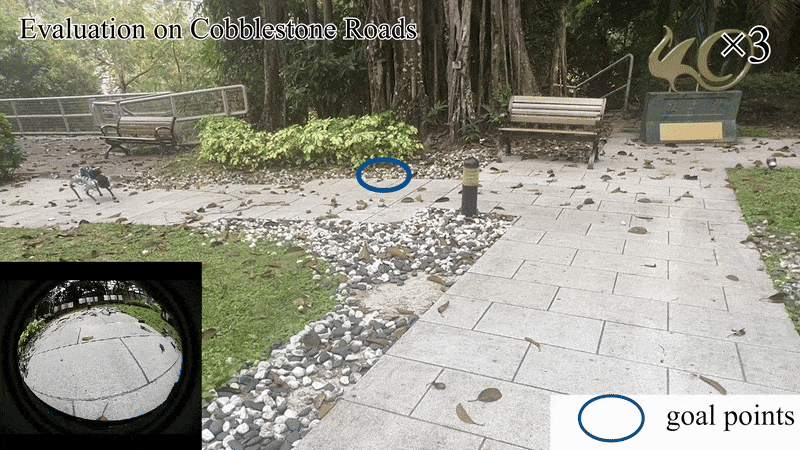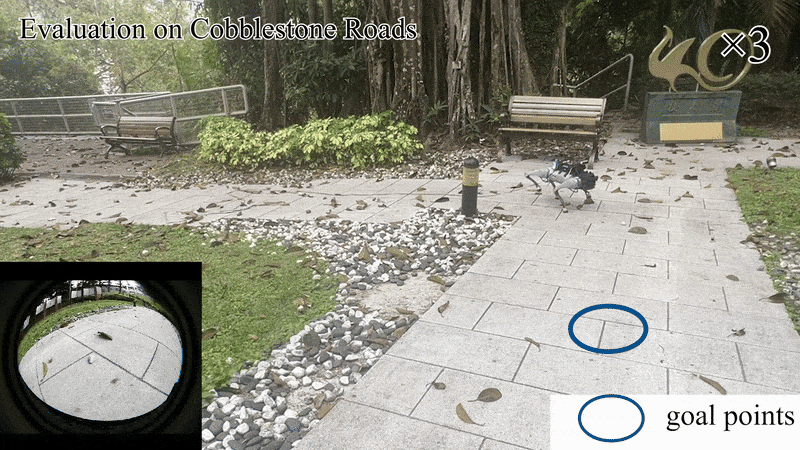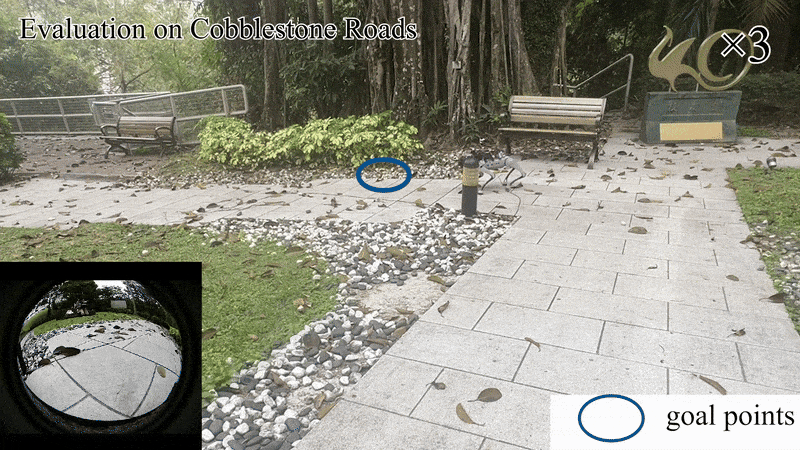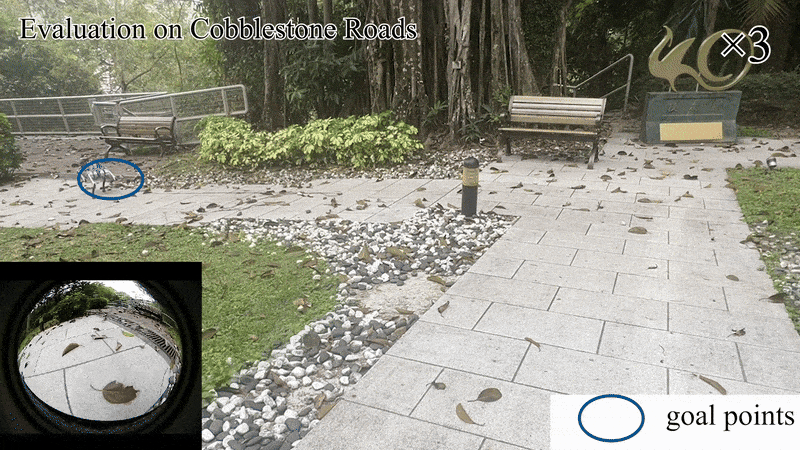
Traversability-Aware Navigation
Traversability-Aware Legged Navigation by Learning from Real-World Visual Data
H. Zhang, Z. Li, X. Zeng, L. Smith, K. Stachowicz, … & and Y. H. Liu
IEEE Transactions on Robotics (T-RO), 2025
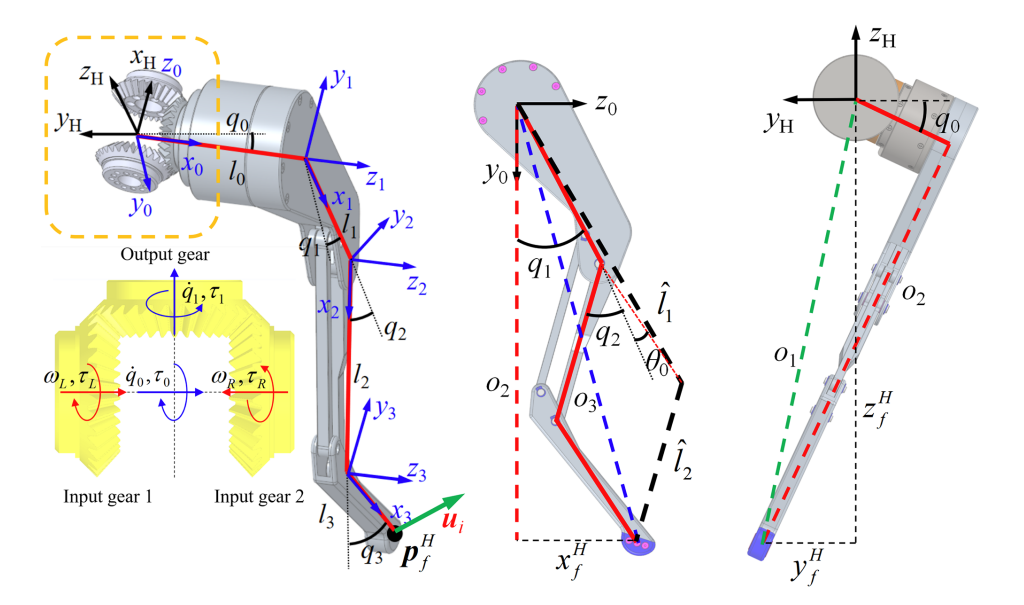
Three-Segment Leg
Codesign of a Differential Three-Segment Leg Enhancing Payload and Efficiency in Quadrupeds
Z. Song, L. Yue, L. Zhang, X. Zeng, H. Zhang, J. Dong, … & Y. H. Liu
IEEE/ASME Transactions on Mechatronics (TMECH), 2025
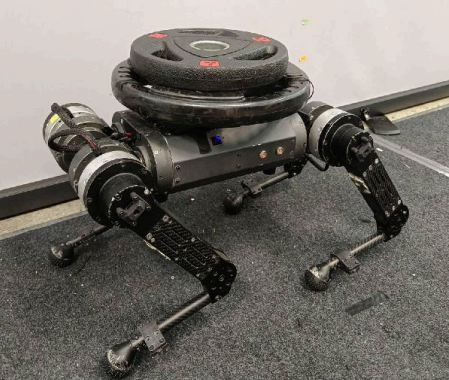
Robust MPC
Robust Model Predictive Control for Quadruped Locomotion Under Model Uncertainties and External Disturbances
W. Xia, L. Yue & Y. H. Liu
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025
Humanoid WBC
Whole-Body Control Framework for Humanoid Robots with Heavy Limbs: A Model-Based Approach
T. Zhang, L. Yue, H. Zhang, L. Zhang, X. Zeng, Z. Song, and Y. H. Liu
arXiv preprint, arXiv:2506.14278, 2025

2024

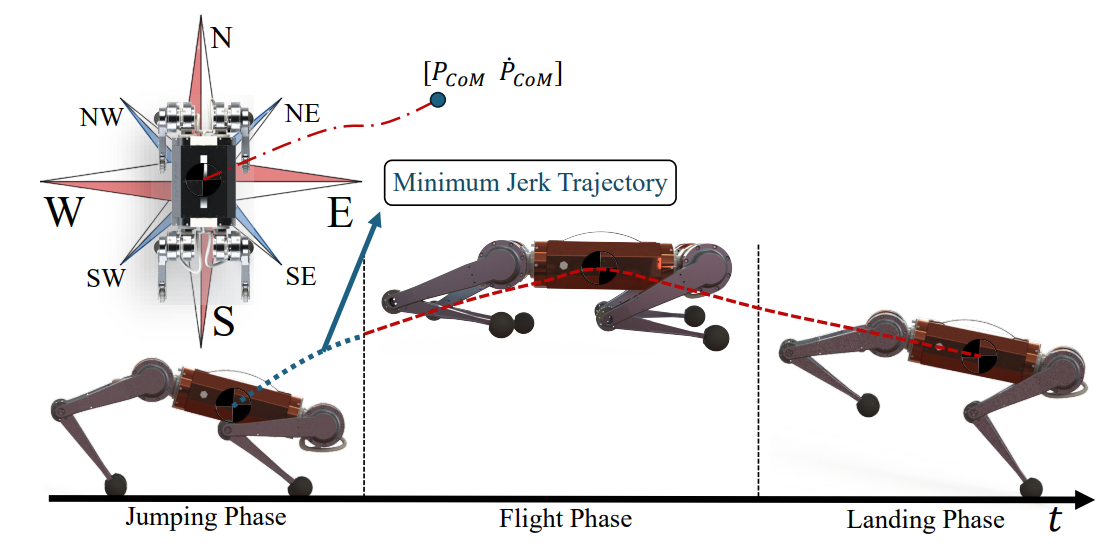
Omnidirectional Jumping
A Fast Online Omnidirectional Quadrupedal Jumping Framework via Virtual-Model Control and Minimum Jerk Trajectory Generation
L. Yue, L. Zhang, Z. Song, H. Zhang, J. Dong, X. Zeng, & Y. H. Liu
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2024
Adaptive MPC
Adaptive Model Predictive Control with Data-driven Error Model for Quadrupedal Locomotion
X. Zeng, H. Zhang, L. Yue, Z. Song, L. Zhang, & Y. H. Liu
IEEE International Conference on Robotics and Automation (ICRA), 2024

2023

Evolutionary Jump Planning
Evolutionary-Based Online Motion Planning Framework for Quadruped Robot Jumping
L. Yue, Z. Song, H. Zhang, X. Zeng, L. Zhang, & Y. H. Liu
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2023
GenLoco
GenLoco: Generalized Locomotion Controllers for Quadrupedal Robots
G. Feng, H. Zhang, Z. Li, X. B. Peng, B. Basireddy, L. Yue, … & S. Levine
Conference on Robot Learning (CoRL), 2023

2022

Optimal Jump Planning
An Optimal Motion Planning Framework for Quadruped Jumping
Z. Song, L. Yue, G. Sun, Y. Ling, H. Wei, L. Gui, & Y. H. Liu
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022